Earth Rover Challenge (1st Place among AI Teams)
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
Oct 2024
Hi! I am a Ph.D. student at the SNU Vehicle Intelligence Lab, advised by Prof. Seung-Woo Seo, expecting to graduate in August 2027.
My research focuses on learning-based navigation for robots in real-world environments, spanning traversability estimation in unstructured terrain, visual navigation, and world models. Going forward, I aim to develop world models and navigation policies that generalize across environments and robot embodiments.
I am currently seeking research internship opportunities in 2027 (Jan–Aug) and full-time research scientist or postdoc positions starting after Aug 2027, in robot learning and embodied AI.
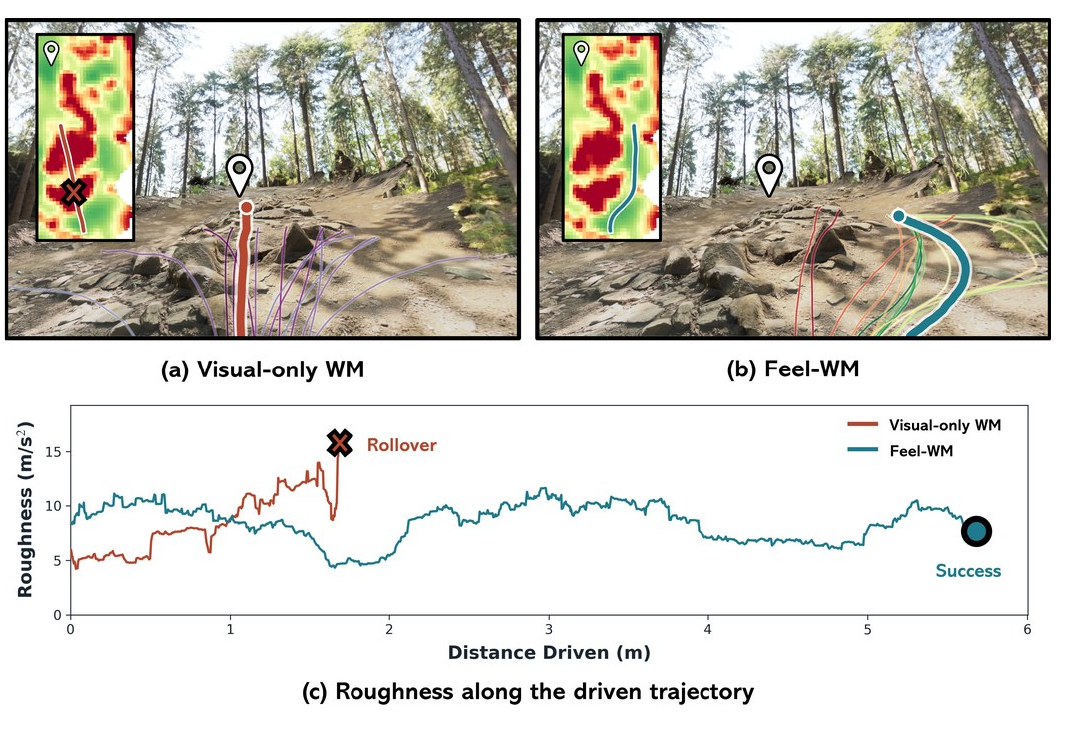

Which Terrain Is Better? Preference Learning with VLM Prototypes for Off-Road Traversability Ranking Under Review
Preprint, 2026
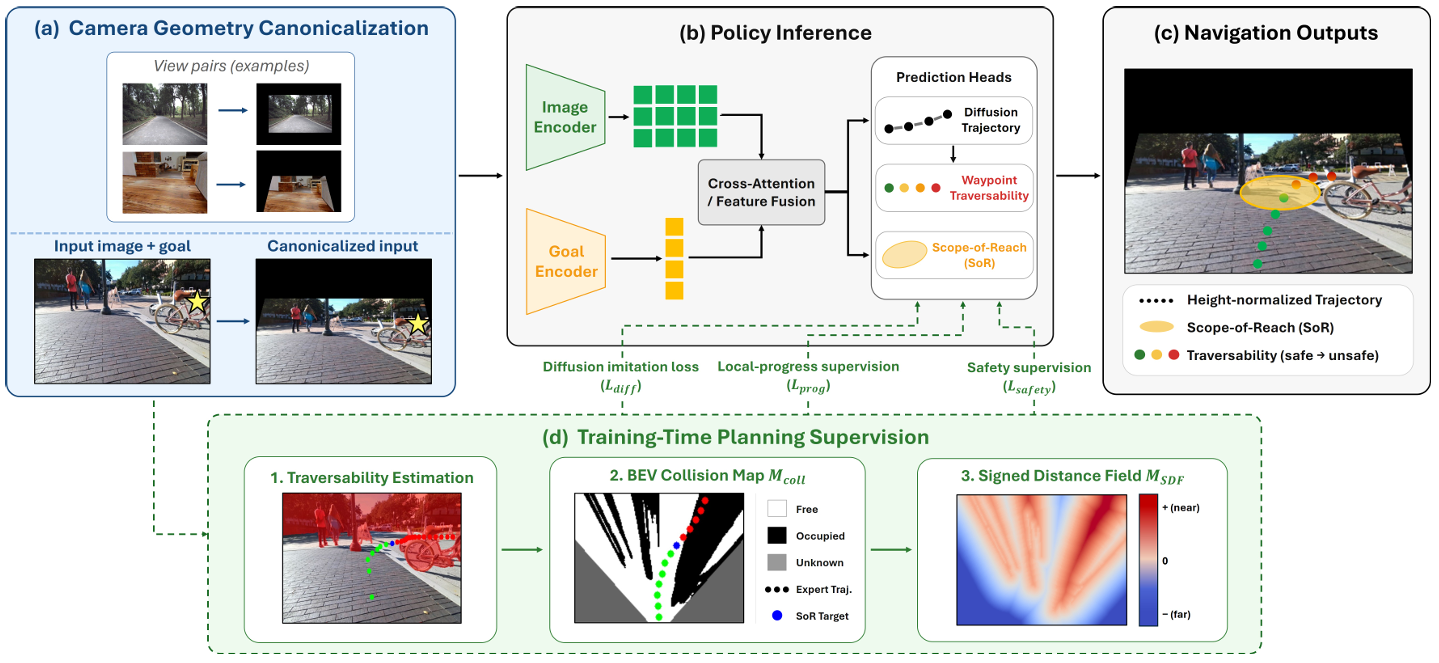
CanonNav: Disentangling Navigation Behavior from Camera Geometry in Cross-Platform Visual Navigation Under Review
Preprint, 2026

Ordinal Neural Collapse as a Representation Prior for Visual Navigation ECCV 2026
European Conference on Computer Vision (ECCV), 2026


Adaptive Robot Traversability Estimation Based on Self-Supervised Online Continual Learning in Unstructured Environments RA-L 2024
IEEE Robotics and Automation Letters (RA-L), 2024
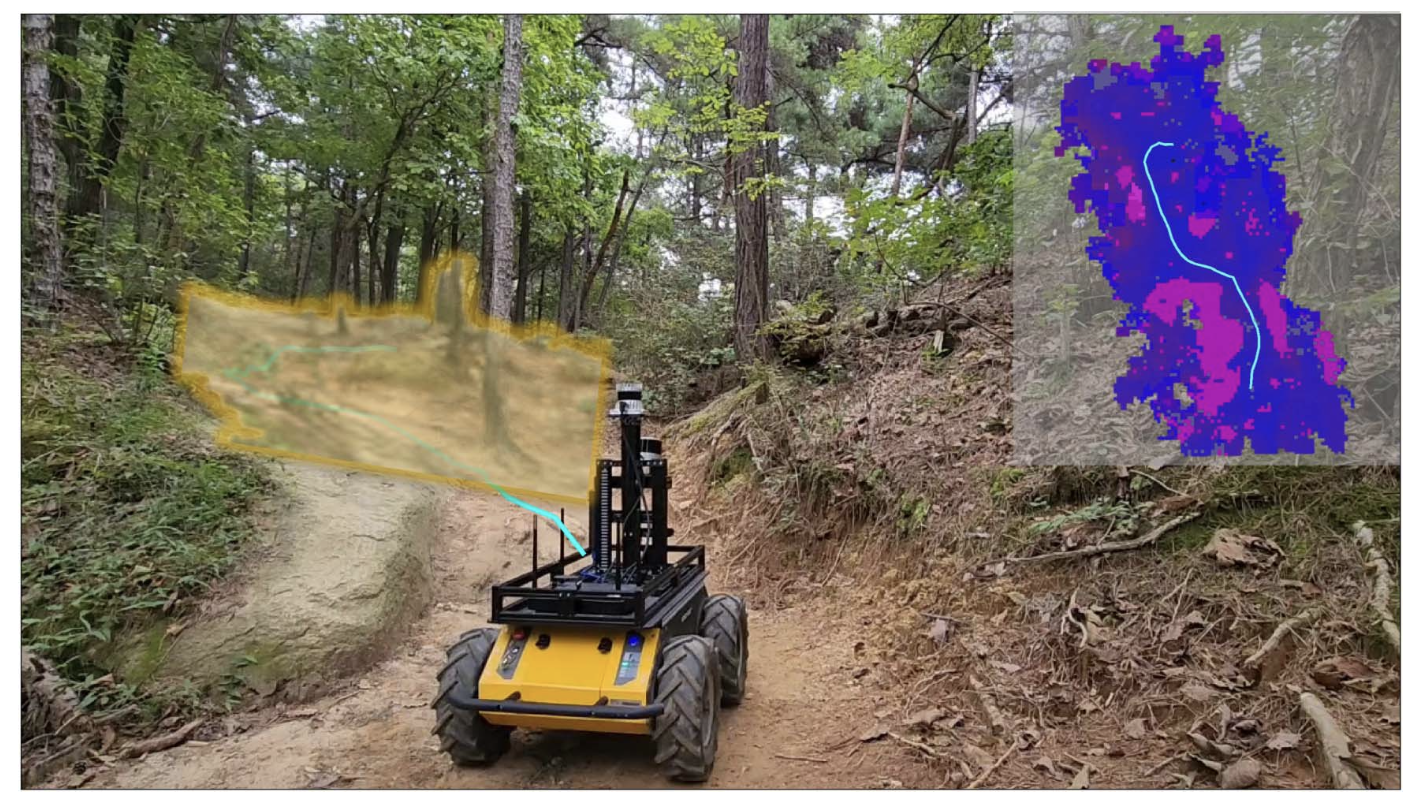
Traversability-aware Adaptive Optimization for Path Planning and Control in Mountainous Terrain RA-L 2024
IEEE Robotics and Automation Letters (RA-L), 2024
Mobile Robot for Autonomous Exploration in Unstructured Environments
Agency for Defense Development (ADD)
End-to-end visual navigation with multi-modal localization for long-horizon missions in unknown, hazardous terrain. I lead the planning stack, from learning-based path prediction to real-time safe replanning (2024 – 2026), and previously developed the path tracking module (2022 – 2023).